
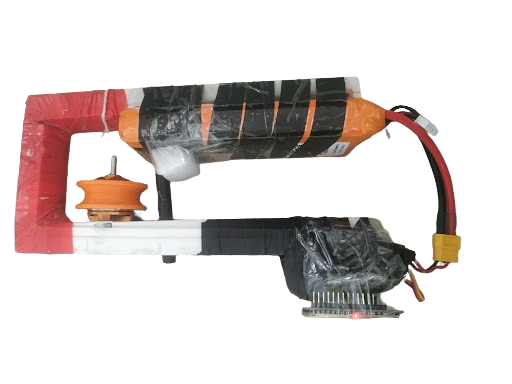
RoboTraverse
A rope-traversing racer built for a robotics club time trial. First place, 10 metres in 2.16 seconds.
Result: 1st placeTime: 2.16s / 10mSpeed: 4.63 m/s
Work Archive
The archive is organized around what each system does, why the architecture was chosen, and what another engineer can inspect in the repository.
A rope-traversing racer built for a robotics club time trial. First place, 10 metres in 2.16 seconds.
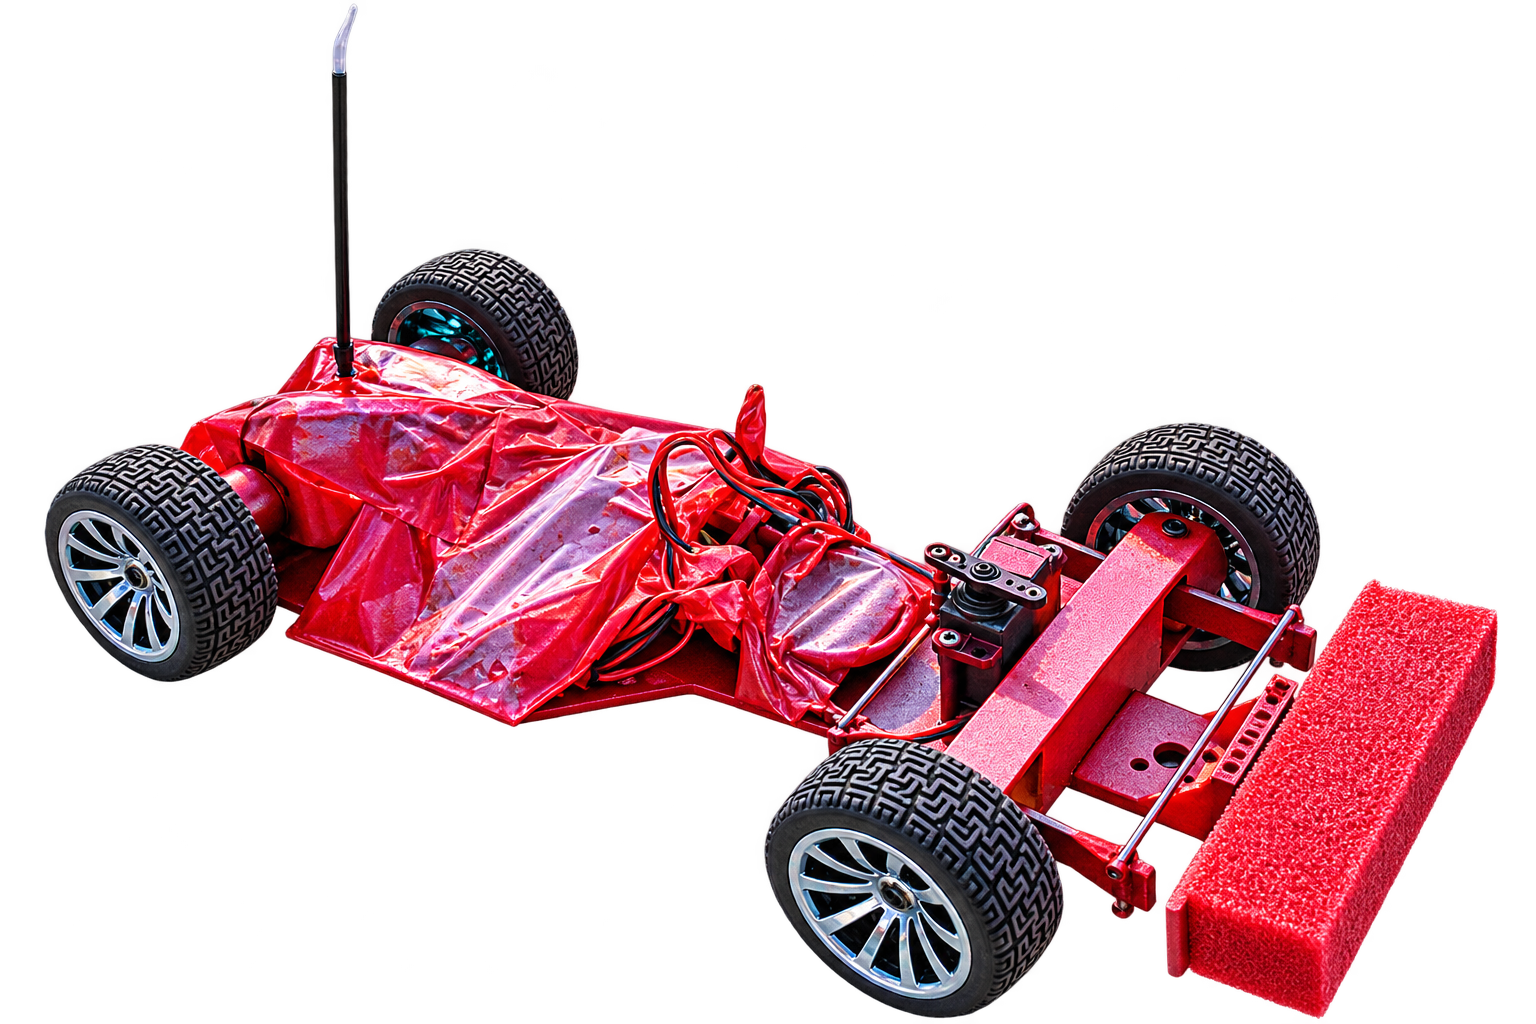
A custom-built dual-BLDC RC racer that won the 24-minute endurance championship at Le Mansar 2026, IIT Jammu, with 28 laps.
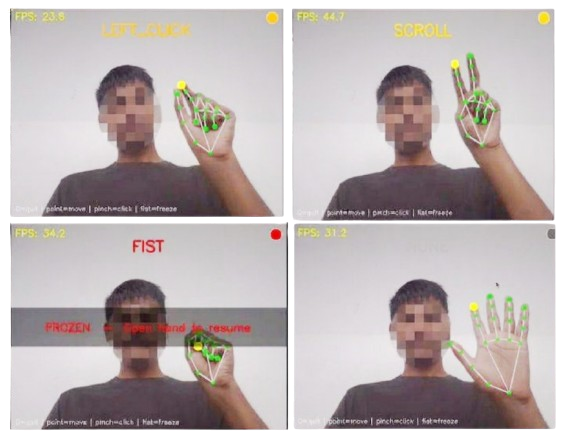
Real-time hand tracking mapped to cursor control, designed to run locally without GPU dependency.
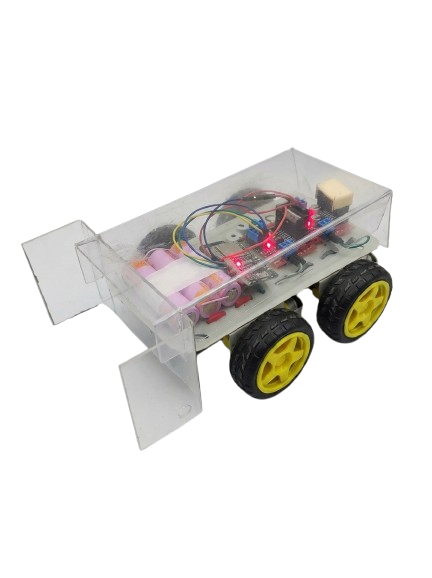
A wireless 4-wheel differential-drive robot with a browser-based multi-touch control interface.
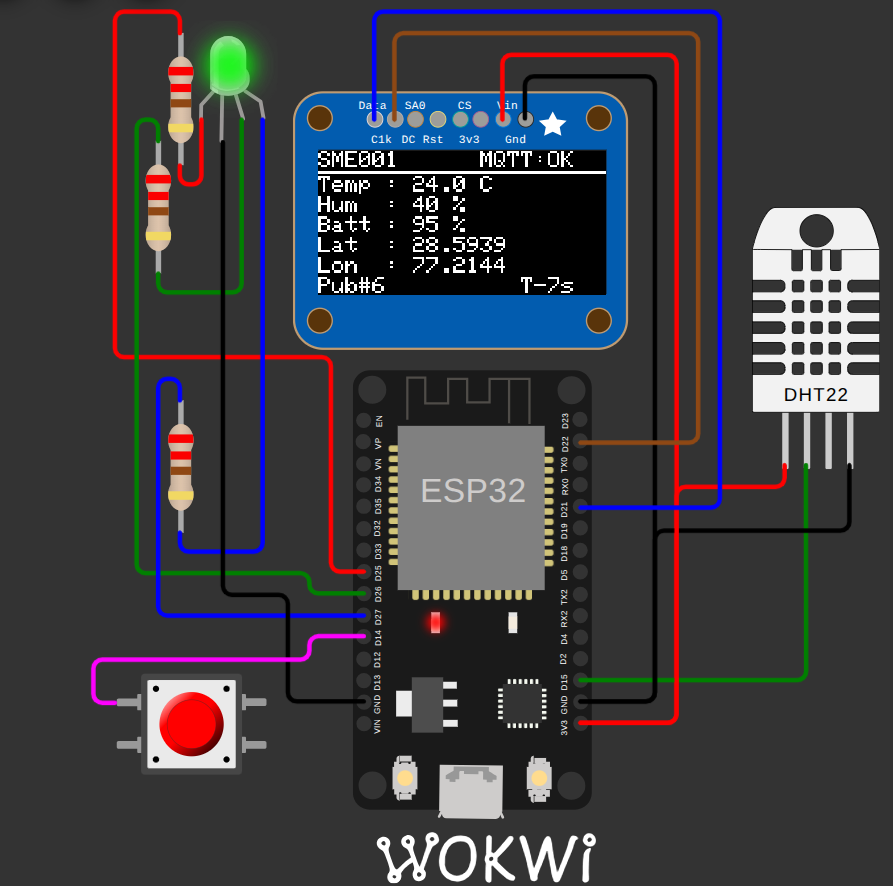
A virtual edge-device environment for testing MQTT telemetry, sensor data, and dashboard flows.